Inertial Motion Unit
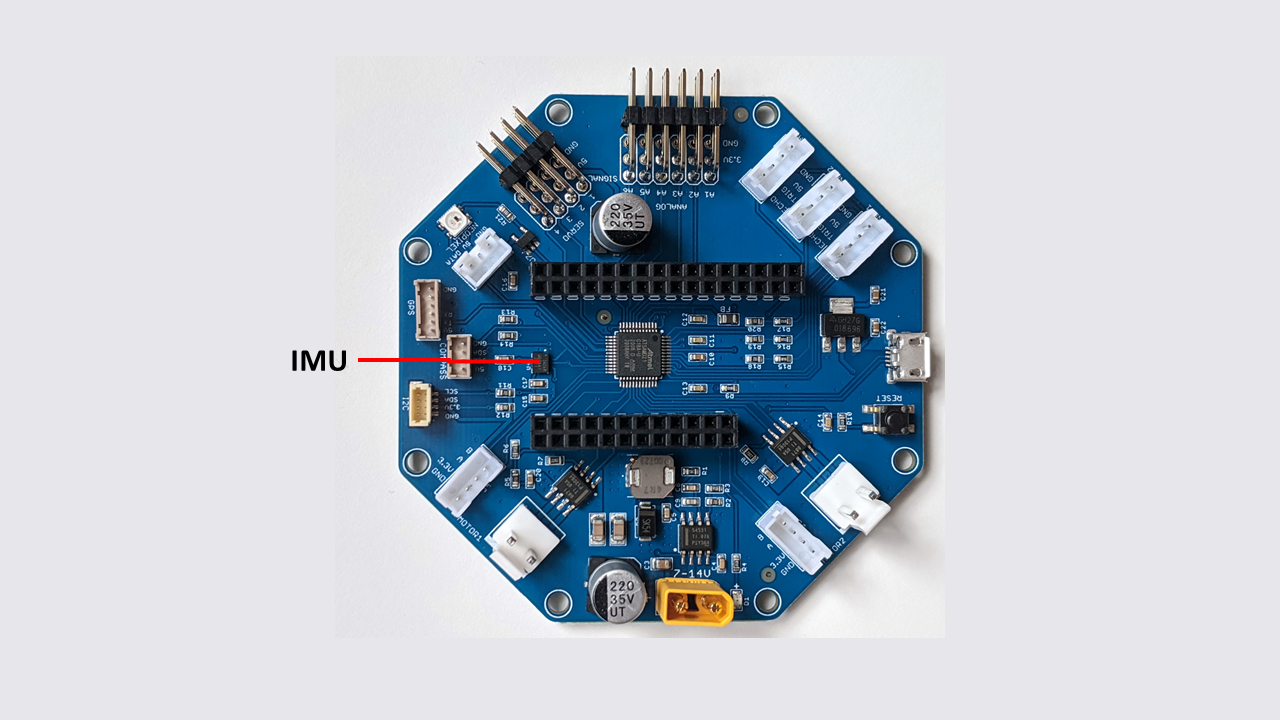
RoverWing contains a Inertial Motion Unit, based on ICM42605 chip by Invensense. This is a 6 degree of freedom sensor (3 axis gyro and 3 axis accelerometer), which can be used for determining robot orientation in space. Provided firmware contains appropriate data fusion algorithm, combining the sensor data and filtering out noise to return the robot orientation, either as roll-pitch-yaw angles, or in a quaternion form. Please see RoverWing Library Guide for details.
Note
Even with noise filtering, data obtained from this sensor alone will always suffer from accumulating error (drift).